Summary
This week's theme centers on making neural surface reconstruction both generalizable and efficient under sparse-view conditions. Representative papers frame the core bottleneck as the mismatch between high-fidelity geometry recovery and the memory, compute, and data demands of dense implicit or volume-based pipelines, motivating surface-focused and sparse representations.
Situation
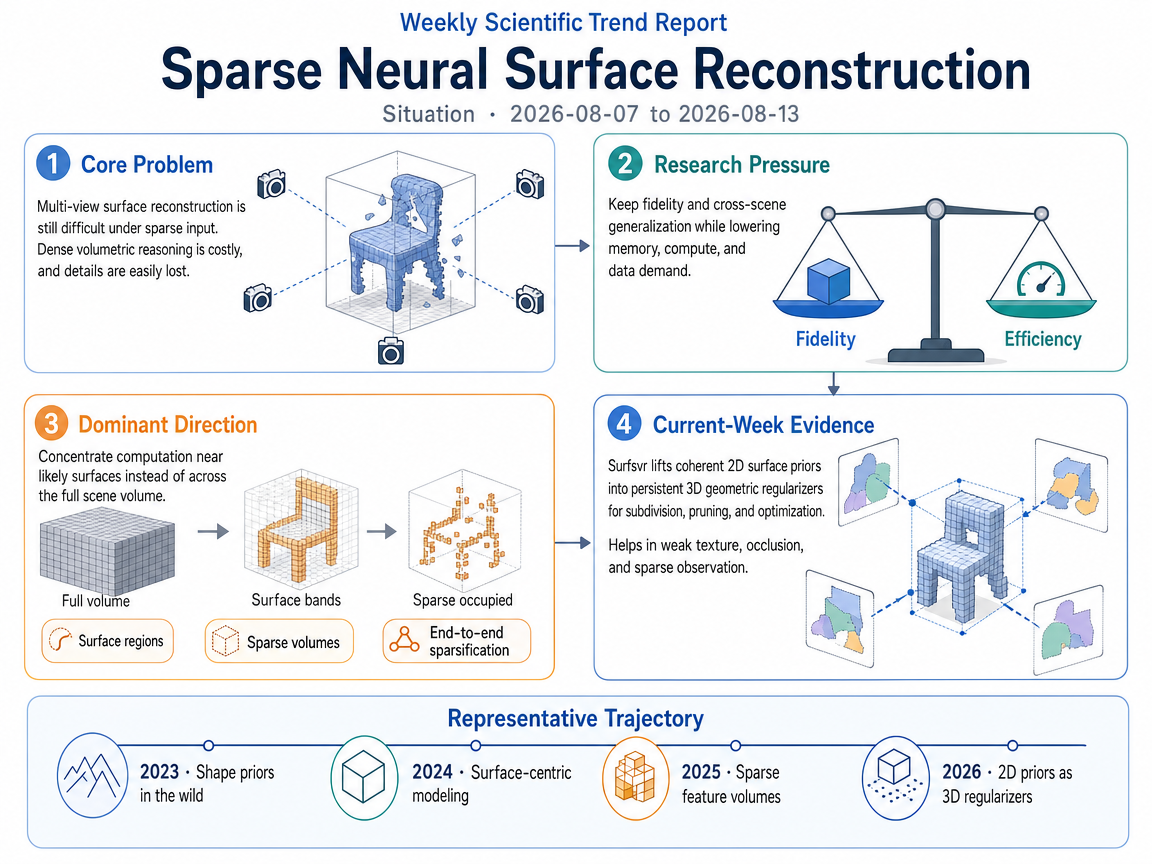
Representative work describes multi-view surface reconstruction as a foundational but still difficult problem: classic pipelines are multi-stage, while neural implicit methods simplify geometry extraction yet often require per-scene optimization, many input views, or dense 3D feature volumes. The main research pressure is to preserve reconstruction fidelity and cross-scene generalization while reducing the cost of dense volumetric reasoning, especially for sparse-input settings where details are easily lost and errors accumulate.
The dominant solution direction is to concentrate computation near likely surfaces rather than across the full scene volume. Surface-Centric Modeling for High-Fidelity Generalizable Neural Surface Reconstruction (2409.03634) emphasizes end-to-end surface-region localization and sparsification, while High-Fidelity and Generalizable Neural Surface Reconstruction with Sparse Feature Volumes (2507.05952) argues that sparse occupied regions are the practical route to higher-resolution generalizable reconstruction. As current-week evidence, Surfsvr: 2D Surface Priors as 3D Geometric Regularizers for Sparse Voxel Reconstruction (2608.11938) extends this trajectory by turning coherent 2D surface regions into persistent 3D constraints, targeting weakly textured, occluded, and sparsely observed areas where purely photometric or visibility-based optimization remains unreliable.
Infographic (English)
Progress
Surfsvr: 2D Surface Priors as 3D Geometric Regularizers for Sparse Voxel Reconstruction <See Details on Fugu-MT>
SurfSVR advances sparse voxel reconstruction by lifting coherent 2D surface priors into explicit 3D geometric regularizers that guide voxel subdivision, pruning, and optimization. Unlike earlier surface-focused sparsification that relies on local photometric or visibility cues, it introduces persistent cross-view surface-level constraints that improve reconstruction in weakly textured, occluded, and sparsely observed regions.
Outlook
Outlook Summary
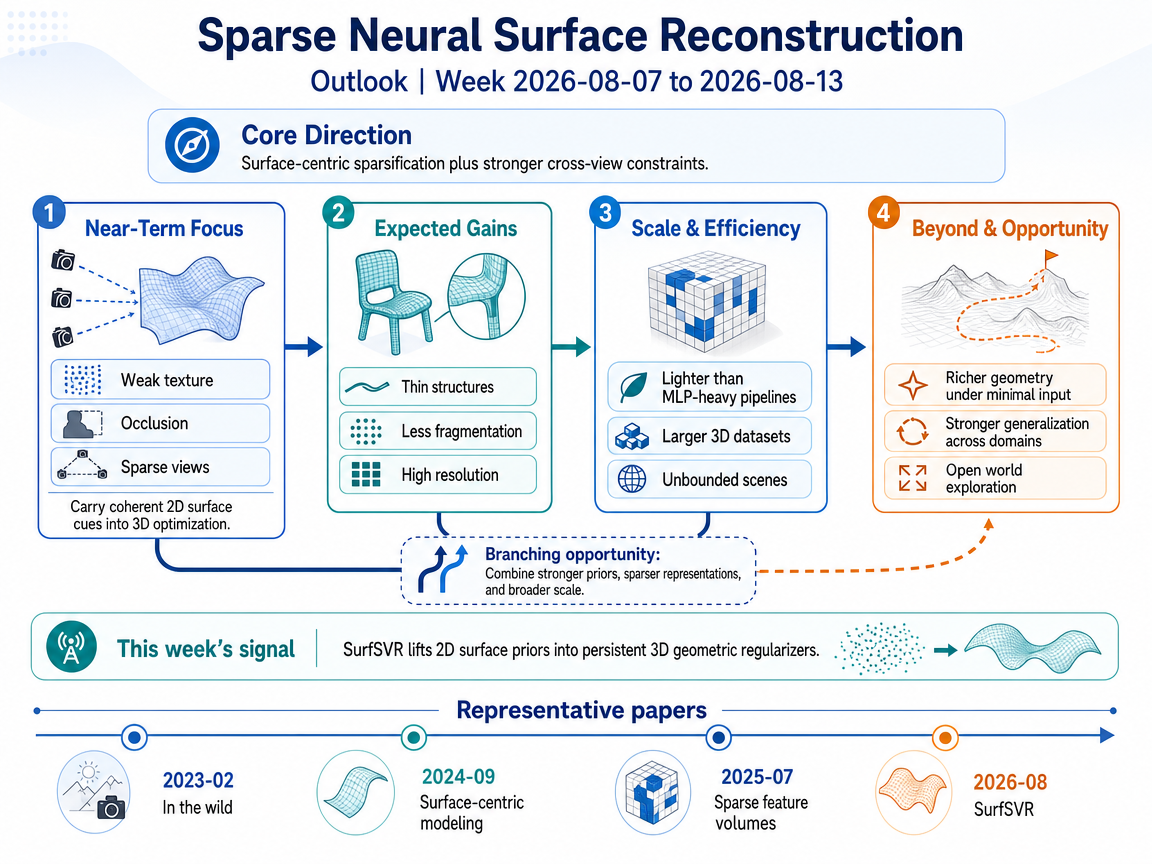
Sparse neural surface reconstruction will likely combine computation focused near probable surfaces with stronger constraints that carry coherent cues across camera views. This should preserve thin structures and reduce fragmentation in weakly textured, occluded, or sparsely observed regions while retaining high resolution. Researchers may also replace heavy MLP-based implicit models with lighter designs, train on broader 3D datasets, and adapt methods from bounded benchmarks to realistic unbounded scenes with varying input-view counts.
Infographic (English)
Three-Year Movement
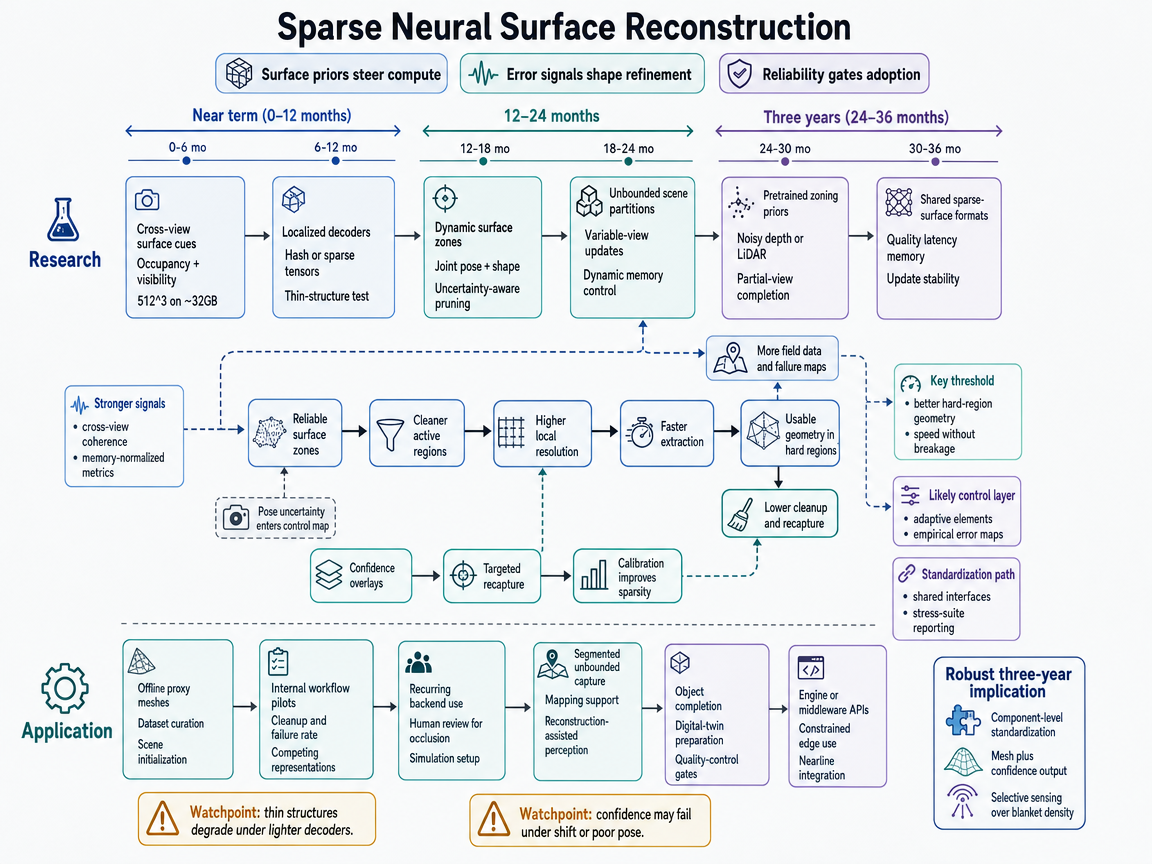
The standard path combines surface-focused sparsification with stronger cross-view guidance and lighter reconstruction components. Coherent surface cues from several images are lifted into 3D, where they guide voxel subdivision and pruning before expensive processing begins. This should concentrate computation more accurately in weakly textured or occluded regions rather than merely reducing the voxel count.
During the first year, researchers are likely to integrate occupancy, visibility, and cross-view surface estimates into complete systems. Tests should examine whether these systems can reconstruct high-resolution geometry on practical hardware while preserving thin structures. Memory use, extraction time, and continuity in difficult regions should be reported alongside average geometry scores. Early applications will remain mostly offline, producing proxy meshes or editable scene assets from sparse sensor observations.
In the second year, surface zones should become dynamic rather than fixed. New observations would update camera poses and local surface probabilities, allowing resolution to move toward regions where evidence has improved. This creates a feedback loop in which cleaner active regions support better geometry, and that geometry helps revise surface locations. Research should also expand from bounded scenes to partitioned outdoor environments with variable numbers of views. By the third year, larger and more varied datasets could support pretrained models that propose useful surface zones for unfamiliar shapes. Shared formats may then let reconstruction components appear in robotics middleware and 3D engines, although human review would remain important for uncertain geometry.
A strong monitoring cue would be repeated gains in both difficult-region quality and end-to-end extraction speed at comparable hardware limits. Progress would weaken if lighter decoders repeatedly erase thin geometry, or if cross-view-guided sparse volumes cannot outperform simpler alternatives on quality and latency. The approach also depends on zones changing as evidence arrives; rigid partitions would not provide the required adaptability.
The contender path adds an explicit error-control layer to surface-focused reconstruction. A learned model proposes the initial surface, but local disagreement between that proposal and sensor observations determines where more work is needed. These residuals, meaning measured mismatches, are combined with uncertainty estimates to refine or remove local surface elements.
During the first year, prototypes should test whether this error-guided approach improves difficult regions at the same memory and runtime as occupancy-only sparsification. Evaluations should include pose errors, occlusion, and thin structures while checking whether high uncertainty actually predicts geometric failure. Early applications may display confidence overlays and unresolved-region flags rather than presenting every reconstructed surface as equally reliable. A system could then request another observation or route a region for human review when the estimated error remains too high.
In the second year, pose uncertainty should enter the same control map as surface uncertainty. This may help distinguish a misplaced camera from genuine local detail and prevent refinement in the wrong location. Active sensing would become more closely linked to reconstruction, so a system could stop after meeting a task-specific error threshold or request a view of an unresolved region. Faster support for changing sparse elements will be essential because irregular refinement can otherwise consume its expected efficiency gains. By the third year, shared confidence formats and validation tests could make this control layer a stable part of reconstruction systems. A likely architecture would combine neural geometry proposals, adaptive surface elements, and an empirical controller that decides where additional sensing or computation is worthwhile.
A key monitoring cue is calibrated uncertainty on withheld views, especially when it supports better occlusion results at matched resource limits. The path weakens if uncertainty does not predict real errors or if fixed occupancy-based systems remain equally accurate and faster. Unlike classical physical simulation, neural reconstruction has no governing equation that guarantees a residual corresponds to a strict error bound. The result would therefore be auditable, task-specific risk control rather than proof that the geometry is correct.
The maybe path turns surface-focused reconstruction into a more structured reliability process. Cross-view surface clues would continue guiding subdivision and pruning, especially where texture is weak or observations are sparse. The additional step is to report where the resulting geometry is uncertain rather than relying only on average accuracy.
During the first year, researchers should publish view-count curves, regional error maps, and memory measurements in the same evaluations. Hard-case tests would emphasize weak texture, occlusion, and limited views, while direct comparisons would show whether cross-view guidance improves on occupancy-only methods. Early applications would remain pilots that deliver a mesh together with a confidence overlay and records of observation coverage. Low-confidence regions could then trigger recapture or human checking. The decisive trigger would be an influential public or industrial buyer requiring a versioned test suite, uncertainty disclosure, and explicit pass criteria.
If that trigger occurs, the second year should bring revised suites designed to reduce overfitting to a fixed collection of cases. Independent replication and tests under unfamiliar conditions would become central, while larger scenes and changing view counts enter later versions. Data gathered from real failures could improve learned shape priors and joint correction of camera pose and surface geometry. By the third year, methods that pass these tests may be selected for recurring mapping or inspection work. Those deployments would generate broader field data, which could improve difficult-case performance and support stricter acceptance rules. Deliverables would combine geometry with regional uncertainty and defined responses for areas that lack adequate evidence.
A strong monitoring cue would be several laboratories adopting the same evolving stress suite, followed by a buyer using its criteria in formal selection. The path is weakened if no coordinating body gains support, cross-view priors fail independent comparisons, or uncertainty becomes unreliable on unfamiliar scenes. Adoption may also remain fragmented because different sectors have different failure costs and no single authority can impose one standard. In that case, reliability reporting could still improve without producing a broadly accepted compliance process.
1-Year / 3-Year Research-Application Infographic
References
- 3D Surface Reconstruction in the Wild by Deforming Shape Priors from Synthetic Data - Authors: Nicolai H\"ani, Jun-Jee Chao and Volkan Isler / <See Details on Fugu-MT> / License: CC-BY-4.0
- Surface-Centric Modeling for High-Fidelity Generalizable Neural Surface Reconstruction - Authors: Rui Peng, Shihe Shen, Kaiqiang Xiong, Huachen Gao, Jianbo Jiao, Xiaodong Gu, Ronggang Wang, / <See Details on Fugu-MT> / License: CC-BY-4.0
- High-Fidelity and Generalizable Neural Surface Reconstruction with Sparse Feature Volumes - Authors: Aoxiang Fan, Corentin Dumery, Nicolas Talabot, Hieu Le, Pascal Fua, / <See Details on Fugu-MT> / License: CC-BY-4.0
- Surfsvr: 2D Surface Priors as 3D Geometric Regularizers for Sparse Voxel Reconstruction - Authors: Yan Di, Chengxi Li, Yaoxing Wang, Mengge Liu, Zhigang Li, Ruida Zhang, Mingyang Li, Pengyuan Wang, Shan Gao, Xiangyang Ji / <See Details on Fugu-MT> / License: CC BY 4.0